
Discontinuous Galerkin Finite Element Method
The DGTD solver provides the time-domain solution of Maxwell's Equations.
| 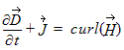 | 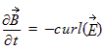 | (1)
|
| 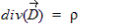 | 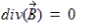 |
|
The mathematical framework of the Discontinuous Galerkin family of numerical methods for Maxwell's equations has been presented by Jan Hesthaven and Tim Warburton [7, 8]. To apply the DG method, we choose basis and test functions local to each mesh element T, in a similar way to the Finite Element Method:
| 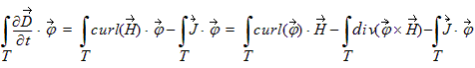 | (2) |
| 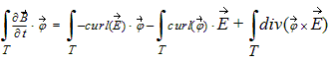 |
|
As is the case with the frequency-domain finite-element solver, the DGTD method is free of spurious solutions [9] and supports higher-order basis functions. In the time domain, the use of high orders minimizes dispersion errors occurring during the simulation of electrically large problems. The DGTD solver not only employs high-order elements but allows mixed element orders in the same mesh, known as hp-adaptivity, to optimize accuracy and solution times.
Following the same approach as in the Finite Volume Method, the divergence term containing volume integrals is transformed into surface integrals:
| 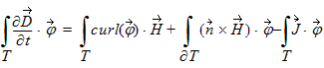 | (3) |
| 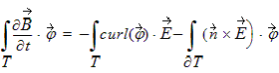 |
|
The tangential fields  and
 are then evaluated as upwind fluxes at the surface of T
by using a Riemann solver [10]. Separating the treatment inside the element
from its surface provides a robust and flexible framework to take into
account boundary conditions. This separation also enables various combinations
of locally implicit and locally explicit time-integration schemes for
instance to achieve an optimum trade-off between speed and memory, without
compromising accuracy and stability.