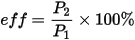Analysis Approach for Universal Motors
For a DC motor, if its field winding is connected in series with its armature winding, it becomes a series motor. When the polarity of the terminal voltage changes, the direction of the produced electromagnetic torque does not change because the armature and the exciting currents alternate their directions at the same time. That means the motor can operate not only with a DC source but also with an AC source. Because it can operate with both DC and AC sources, a series motor is also called universal motor (UniM).
For a universal motor, the stator is equipped with p pairs of coil-wound poles, creating P pairs of alternating north and south poles. The coil excitation may be either AC or DC. The rotor is equipped with a distributed winding connected to a commutator that revolves together with the rotor.
A system of brushes is kept in permanent electrical contact with the commutator. When AC or DC current is applied to the rotor winding (via the brushes and commutator) a torque is produced by the interaction of the rotor (armature) currents and the field produced by the stator poles.
The commutator causes the armature to create a magnetic flux distribution whose axis is perpendicular to the axis of the field flux produced by the permanent magnets. For these motors, the commutator acts as a mechanical rectifier.
The performance of a universal motor is analyzed in the frequency domain. The voltage equation of a universal motor is
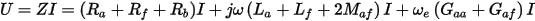
where, Ra,Rf, and Rb are the armature resistance, field winding resistance, and the brush contact resistance, respectively. La, Lf, and Maf are the armature self inductance, field winding self inductance, and their mutual inductance, respectively, and are linearized nonlinear parameters. Gaa and Gaf are the coefficients of motion induced voltages by the armature and field winding currents, respectively, and are also linearized nonlinear parameters. w is the radian frequency, and we the rotor speed in electric rad/s. Z is equivalent input impedance. When the brush axis is aligned with q-axis, Maf = Gaa = 0.
For a given rotor speed we, armature current can be computed based on the applied voltage U, as

The input power (electric power) is directly computed from voltage and current as
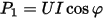
The output power (mechanical power) is
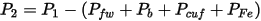
where Pfw, Pb, Pcua, Pcuf, and PFe are frictional and wind loss, brush drop loss, armature copper loss, field winding copper loss, and iron-core loss, respectively.
The output mechanical shaft torque T2 is

The efficiency is computed by